R&D platform · Self-balancing prototype
PAW
Self-balancing platform
A compact platform that balances on two wheels, demonstrated on flat surfaces.
- Two driven wheels, one on each leg
- Carry handle, compact body
- Balancing demonstrated on flat surfaces
- Mechanical CAD and working prototype
The project
Where it stands
The platform
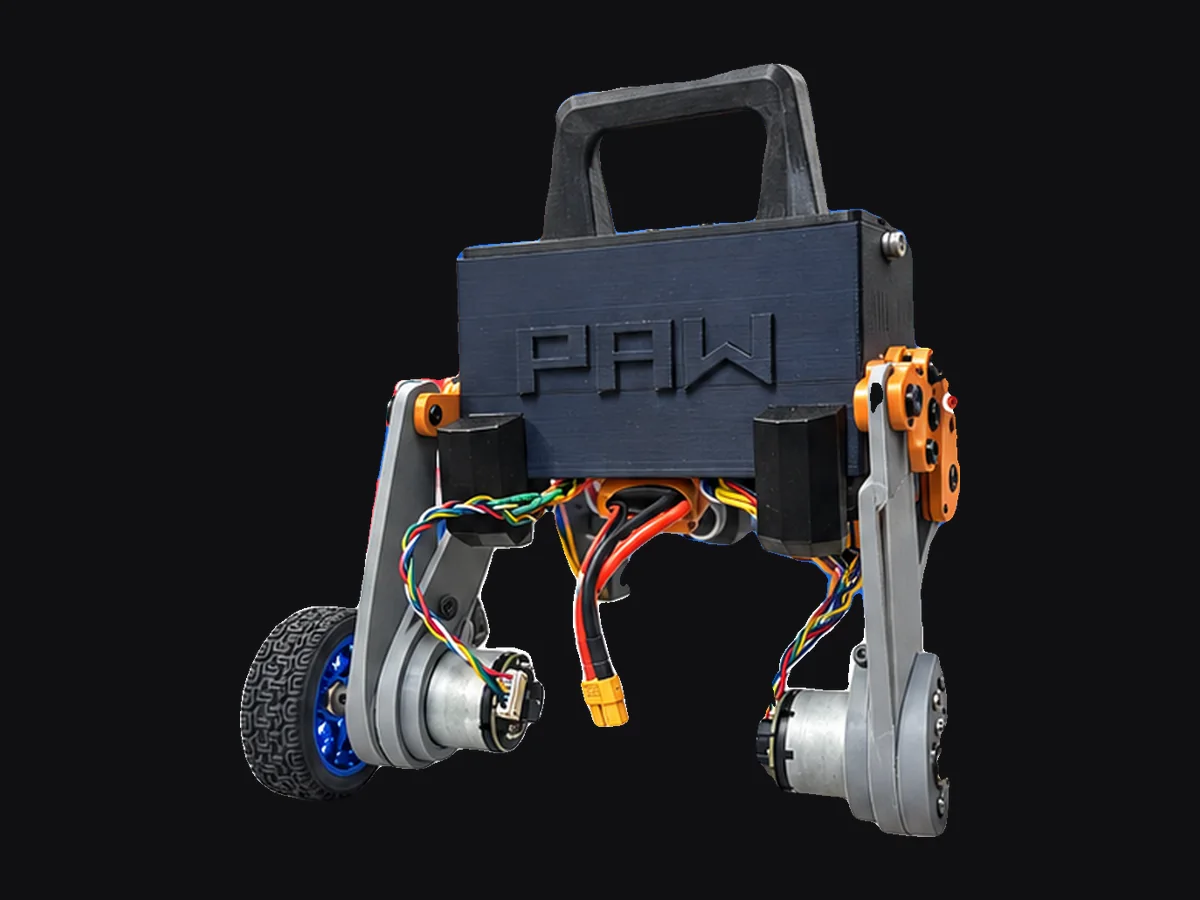
PAW is a compact self-balancing platform: a body with a carry handle on two wheels, each wheel on its own leg.
Self-balancing prototype
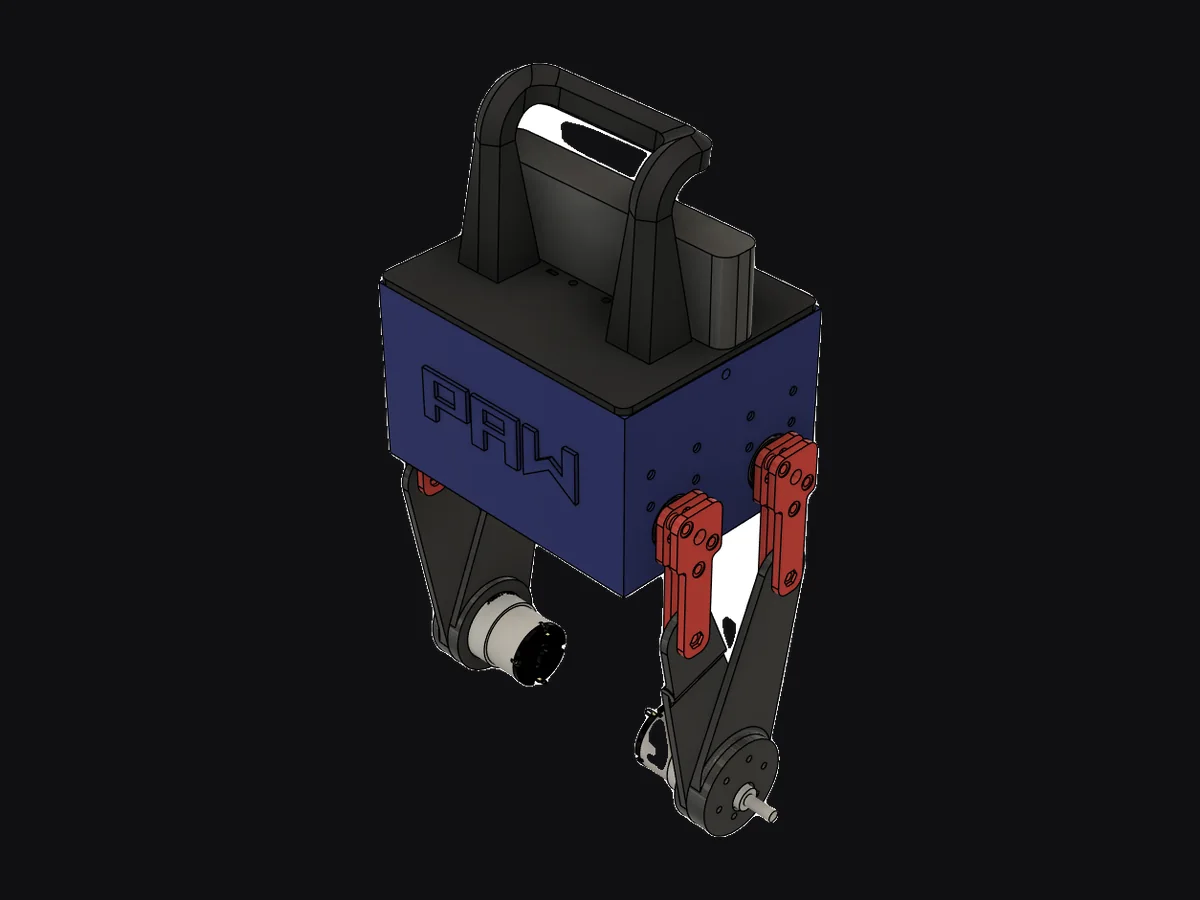
The prototype balances on flat surfaces. The mechanical CAD and the working prototype match.
What comes next
Uneven ground. The legs are there so the platform can adapt to terrain, and that is the work ahead.
Pictures
CAD and hardware
Our own research
Other platforms
Mechanized Titan
A four-legged research platform: a simulation model and a built prototype that crawls.
Open → Working prototypeOmniDrive
A mobile base that moves in any direction, with a modular payload deck.
Open → In developmentVision-Swerve
A base with four steered wheel modules; chassis, drive electronics and camera integration under way.
Open → CAD and fabricated partsTERRA-Nav
A tracked platform for rough ground; navigation proven in simulation, outdoor tests next.
Open →Start here
Need a platform like this?
We build research platforms and test rigs to order, starting from a design we have already proven.